
Robot Arm Degrees of Freedom Explained
Robot arm degrees of freedom explained: what DOF means, 6-axis vs 7-axis tradeoffs, reducer counts, and how to match axes to your application.
 August 20, 2026
 > Robot Arm Degrees of Freedom Explained
One number defines what a robot arm can do: its degrees of freedom, usually written as DOF. This single figure determines how many independent ways the arm can move, what workspaces it can reach, and how flexibly it can orient its tool. It is also one of the first specifications a buyer sees on a datasheet and one of the least understood. For engineers designing arms and for buyers comparing them, a clear picture of what DOF really means, and how it connects to the joints and components inside the machine, is worth the time to build.
What Are Degrees of Freedom?
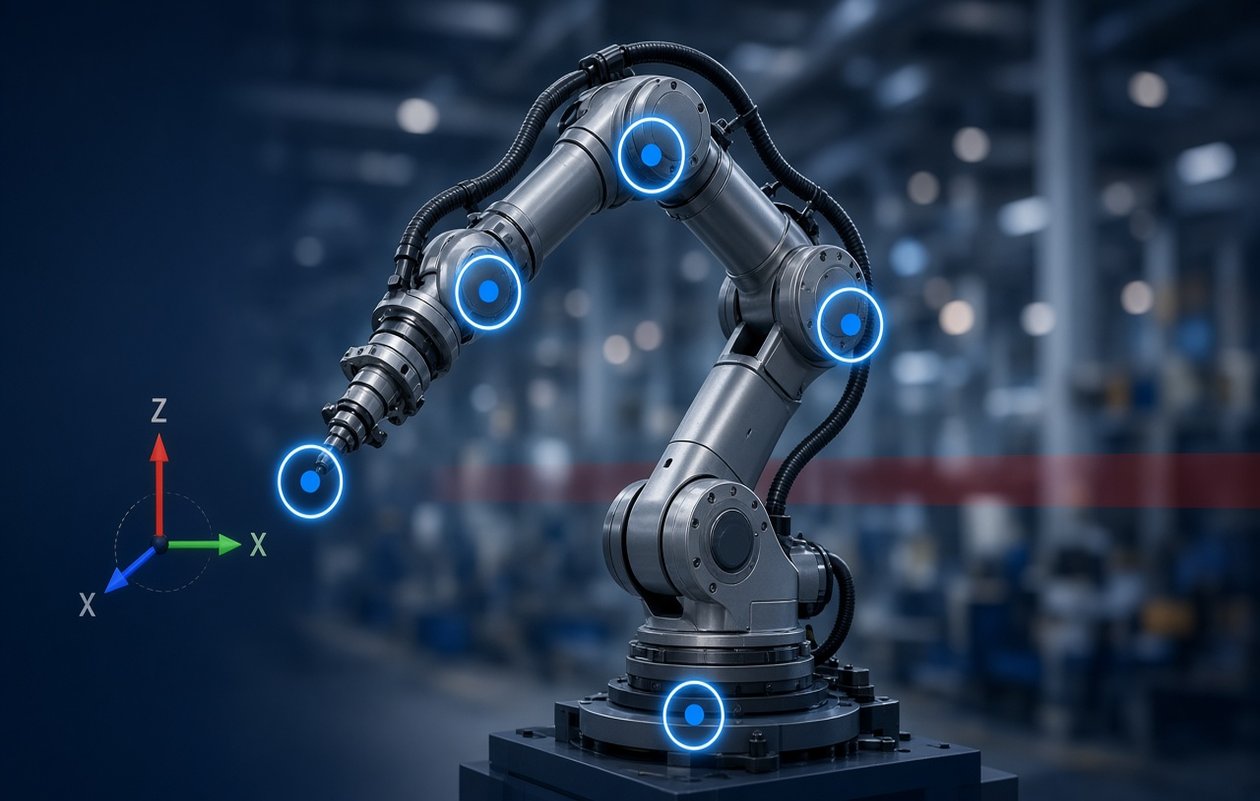
A degree of freedom is one independent axis of motion. In a rotating joint, it is one axis around which the joint can turn. A six-axis articulated robot typically has six independently controlled axes, providing six degrees of freedom, which allows it to move its tool to any position within its workspace and orient it in any direction. More DOF means the arm can reach more positions and orientations, but it also means more motors, more weight, more cost, and more control complexity. The number is therefore a design decision as much as a specification, chosen to match the tasks the arm will actually perform.
Position: X, Y, Z
Orientation: roll, pitch, yaw
1 DOF = 1 joint
More axes = more cost
Orientation: roll, pitch, yaw
1 DOF = 1 joint
More axes = more cost
6-Axis vs 7-Axis Arms
| Feature | 6-Axis Arm | 7-Axis Arm |
|---|---|---|
| Independent axes | 6 | 7 |
| Pose control | Full workspace placement and orientation | Redundant paths to same pose |
| Typical applications | Welding, palletizing, machine tending, assembly | Confined spaces, obstacle avoidance, humanoid arms |
| Reducer count | Six harmonic reducers typical | Seven reducers typical |
| Control complexity | Standard kinematics | Redundant kinematics |
The 6-Axis Workhorse
Six axes cover the three position coordinates, X, Y, and Z, and the three orientation angles, roll, pitch, and yaw. With these, a 6-axis arm can place a tool at any point in its workspace with any orientation. That is sufficient for most industrial tasks, including welding, palletizing, machine tending, and many assembly operations. The 6-axis articulated arm is the workhorse of the industry for exactly this reason: it provides six-axis pose control with a relatively simple and widely used architecture.
The 7-Axis Advantage
The seventh axis adds what engineers call redundancy. A 7-axis arm can reach the same position and orientation in more than one way, which means it can route around obstacles, work inside confined spaces, or keep its wrist at a favorable posture while the rest of the arm adjusts. Some collaborative arms and many humanoid arm designs use seven or more axes, especially when redundancy and obstacle avoidance are important, because their environments are less structured and their tasks more varied. The cost is an extra joint, with its motor, reducer, and drive, and the added control complexity of handling a redundant system.
How DOF Relates to Joints and Reducers
Every degree of freedom is a physical joint, and every joint needs a transmission. A 6-axis arm typically uses six harmonic reducers, one per axis, sometimes mixed with other reducer types in the shoulder and wrist. A 7-axis arm needs seven. The direct translation from DOF to component count is one of the main reasons the motion layer dominates the cost of a robot arm, and it is why the quality of those components sets the real world performance ceiling. An arm is only as precise as its least precise joint, because errors add up along the kinematic chain.
Choosing DOF for Your Application
| Application | Recommended DOF | Rationale |
|---|---|---|
| Simple pick and place | 4 axes | Task envelope may not require full orientation control |
| Complex assembly or machining | 6 axes | Full pose control for industrial tasks |
| Confined space work | 7 axes | Redundancy helps route around obstacles |
Match DOF to the Task, Not the Hype
The right number of axes depends on the task, not on what looks impressive on a datasheet. A simple pick and place application may only need four axes. Complex assembly or machining benefits from six. Confined space work, where the arm must reach around obstacles, benefits from seven. Every unnecessary axis adds cost and failure modes without adding value, so the disciplined approach is to define the task envelope first and let the DOF requirement fall out of it.
Plan for the Components Early
The DOF budget should be decided early, because it drives the number of motors, reducers, and drives in the bill of materials, and those components have long lead times. Sizing each joint, choosing the reducer for each axis, and locking the architecture before prototyping avoids expensive redesigns later. Teams that treat DOF as a mechanical architecture decision, rather than a number to fill in on a spec sheet, are the ones that hit their cost and performance targets.
Common Misconceptions About DOF
Degrees of freedom require careful evaluation rather than surface-level comparisons:
DOF is not precision: Accuracy depends on individual joint quality, not the total joint count.
DOF is not workspace: Link lengths dictate reach, meaning two arms with identical DOF can operate in completely different workspaces.
Datasheets hide control reality: DOF counts only reflect independently controllable joints, not software capabilities. A well-controlled 6-axis arm will consistently outperform a poorly controlled 7-axis arm.
Degrees of Freedom in Context
The DOF concept extends beyond stationary arms. Mobile robots add axes through wheels or legs, mobile manipulators combine base and arm motion, and end effectors introduce their own independent axes. Additional axes generally increase system capability while also adding hardware, control, integration, and cost considerations.
The recent push toward higher DOF is driven by deployment in unstructured environments and advancements in control software for redundant systems. However, advanced software does not eliminate physical hardware costs, making DOF selection a design optimization problem rather than a quest for the highest number.
Buyers must evaluate DOF alongside underlying joint quality. An advertised 7-axis arm means little if the underlying reducers lack precision. Inspecting reducer types, backlash specifications, and rated joint life reveals true capability and provides an accurate baseline when comparing competitive quotes.
FAQ
Is more DOF always better?
No. More DOF means more cost, weight, and complexity. Choose the minimum that achieves the task.
Why do humanoid arms need 7 or more DOF?
Redundancy lets them avoid obstacles and match human-like motion, which is valuable in unstructured environments.
Do all 6-axis arms use harmonic reducers?
Most use harmonic or RV reducers in the wrist and shoulder joints for precision and compactness.
How does DOF affect cost?
Each DOF adds a motor, reducer, encoder, and drive, which are the dominant cost drivers in a robot arm.
Designing an arm and need help sizing the joints? The engineering team at Laifual Drive can review your requirements and recommend a transmission solution for robotic applications.